UAV Flight Controller Guide: Choosing an Autopilot, GNSS and RTK
What to compare when choosing a UAV flight controller: processor, sensor redundancy, interfaces and vehicle support, plus SIYI GNSS and RTK positioning modules.
Autopilot · Flight Controller
ArduPilot / PX4 autopilot with STM32H7, redundant dual IMUs and built-in shock absorption
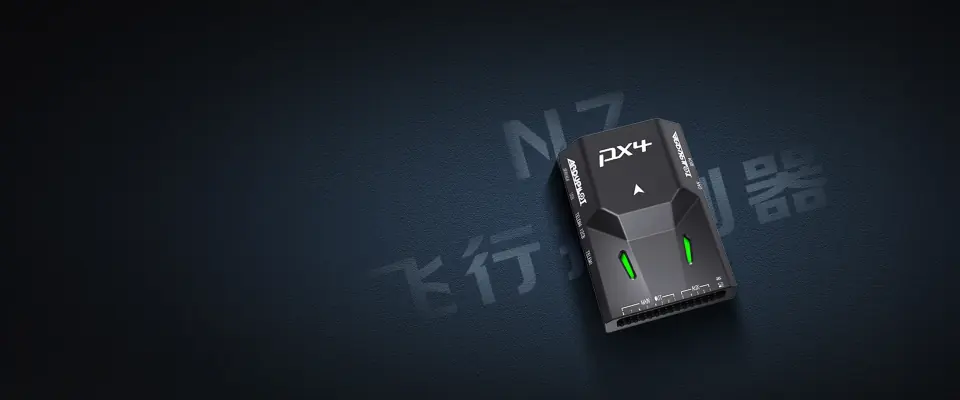
N7 is an ArduPilot / PX4 autopilot built on an STM32H7 processor at 480 MHz with an STM32F103 co-processor. It has dual-redundant IMUs, an internal shock-absorbing structure and IMU heating for low temperatures. With 4 UART ports, 1 CAN port and 8 standard PWM plus 5 programmable IO, it serves planes, multirotors, helicopters, VTOLs, UGVs and USVs. It measures 47 x 68 x 19 mm and weighs 57 g.
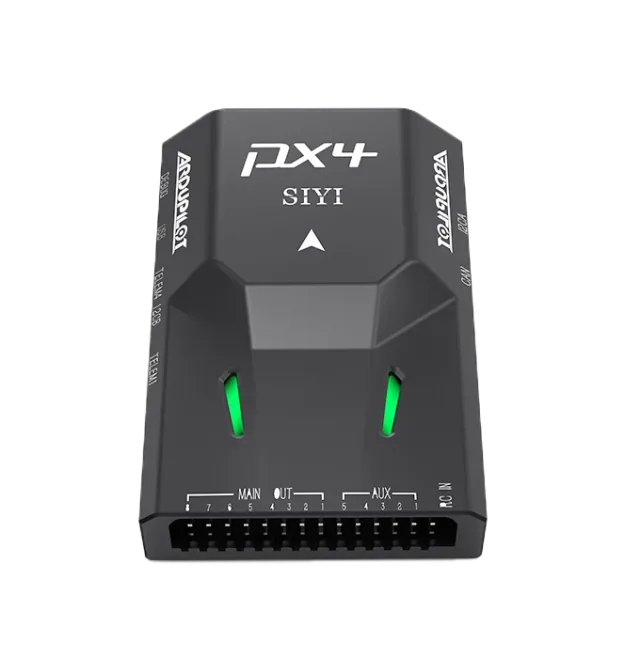
The STM32H743IIK6 (Arm Cortex-M7, 480 MHz, 2 MB flash, 1 MB RAM) has a double-precision floating-point unit. An STM32F103 (Cortex-M3, 72 MHz) serves as co-processor.
BMI088 and ICM20689 IMUs back each other up. Magnetometer redundancy pairs the onboard IST8310 compass with the compass in the GPS module. The barometer is an MS5611.
Eight standard PWM IO and five programmable IO sit alongside SBUS / PPM RC input, a power module input, a GPS & safety port, USB Type-C and a TF card slot.
An internal shock-absorbing structure suits a range of airframes, and built-in heating resistors keep the IMU at a constant temperature in low-temperature environments.
Runs PX4 or ArduPilot firmware on planes, multirotors, helicopters, VTOLs, UGVs and USVs, and is used with QGroundControl and Mission Planner.
Operates from -20 ℃ to 65 ℃ on a 4.5–5.5 V power module input, with a servo voltage input of 0–10 V. A flight controller power module is included in the package.
| Main Processor | STM32H743IIK6 (32 Bit Arm® Cortex®-M7, 480 MHz, 2 MB memory, 1 MB RAM) |
|---|---|
| Co-processor | STM32F103 (32 Bit Arm® Cortex®-M3, 72 MHz, 20 KB SRAM) |
| Accelerometer / Gyro | BMI088 / ICM20689 |
|---|---|
| Electronic Compass | IST8310 |
| Barometer | MS5611 |
| UART Serial Port | 4 |
|---|---|
| I2C | 3 |
| CAN | 1 |
| PWM Output | 8 x Standard PWM IO 5 x Programmable IO |
| RC Input | SBUS, PPM |
| Power Module Input | 1 |
| GPS & Safety | 1 |
| USB (Type-C) | 1 |
| TF Card Slot | 1 |
| Compatible Model | PX4 / ArduPilot Firmware (Planes / Multirotors / Helicopters / VTOL / UGV / USV) |
|---|---|
| Power Module Voltage Input | 4.5 ~ 5.5 V |
| USB Voltage Input | 5 V (±0.25 V) |
| Servo Voltage Input | 0 ~ 10 V |
| Working Temperature | -20 ℃ ~ 65 ℃ |
| Dimensions | 47 x 68 x 19 mm |
| Weight | 57 g |
N7 Autopilot
Item names as listed by SIYI. Contents can vary by combo.
Specifications are taken from the SIYI website as of 1 October 2026 and may be revised by the manufacturer without notice. View this product on the SIYI website
Based on the reference configurations and case studies SIYI has published that use this product.
SIYI reference configurations that include this product.
Files are served by SIYI, as listed on 1 October 2026. Check the SIYI download page for the latest versions.
The flight controller is supplied with 4.5–5.5 V.
No. The pins carry no output voltage; power has to come from an external supply.
N7 runs open-source firmware and supports both ArduPilot and PX4. Using it requires knowledge of open-source flight controller setup and tuning.
It has 4 UART serial ports, 3 I2C, 1 CAN, 8 standard PWM IO plus 5 programmable IO, RC input (SBUS, PPM), 1 power module input, 1 GPS and safety switch port, 1 USB Type-C port and 1 TF card slot.
This requires a propulsion system that supports the CAN protocol.
Add an external vibration damping plate to the installation.
What to compare when choosing a UAV flight controller: processor, sensor redundancy, interfaces and vehicle support, plus SIYI GNSS and RTK positioning modules.
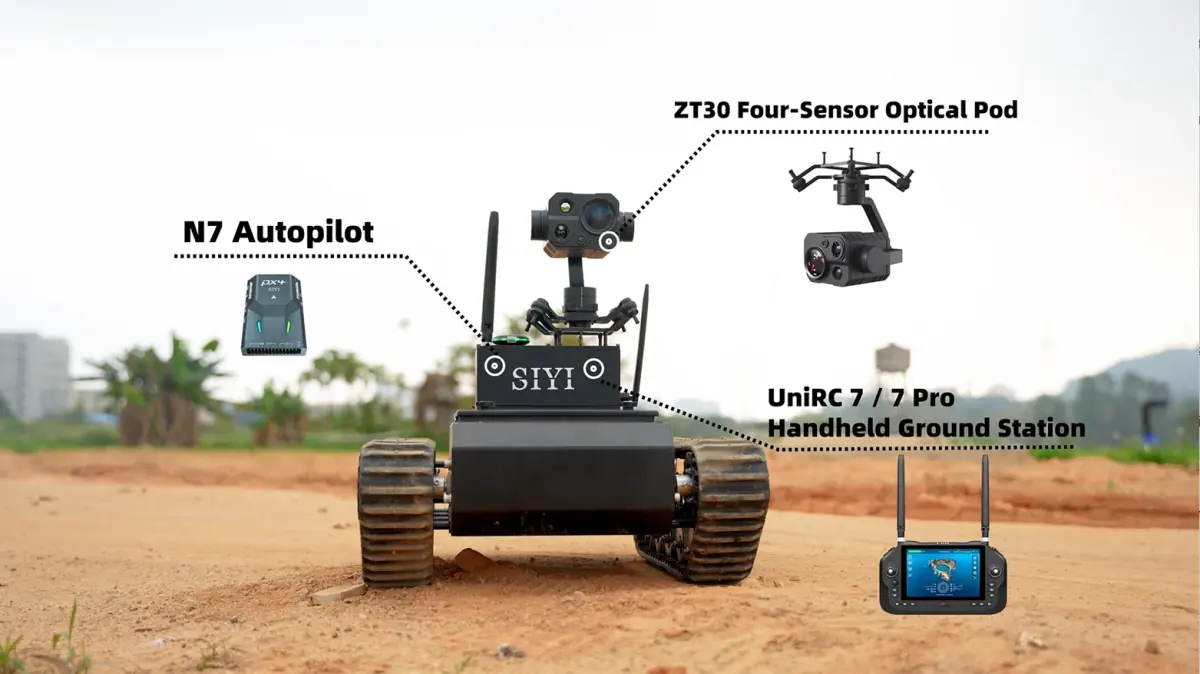
SIYI's integration exercise puts the N7 autopilot, UniRC 7 and A8 mini on a tracked inspection UGV running ArduPilot Rover: set-up, steps and what carries over from drones.
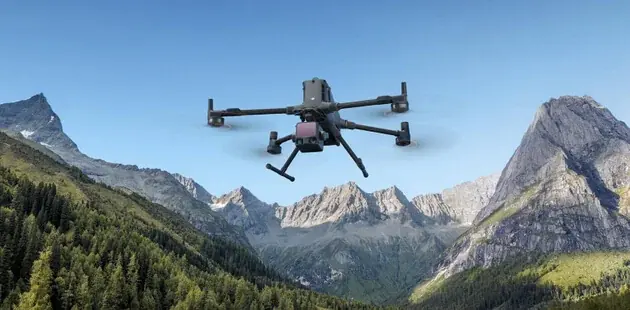
How SIYI combines the ZT30 thermal gimbal camera, UniRC 7 Pro ground station, N7 autopilot and UniGCS for forest and wildlife patrol drones, and the effect it reports.
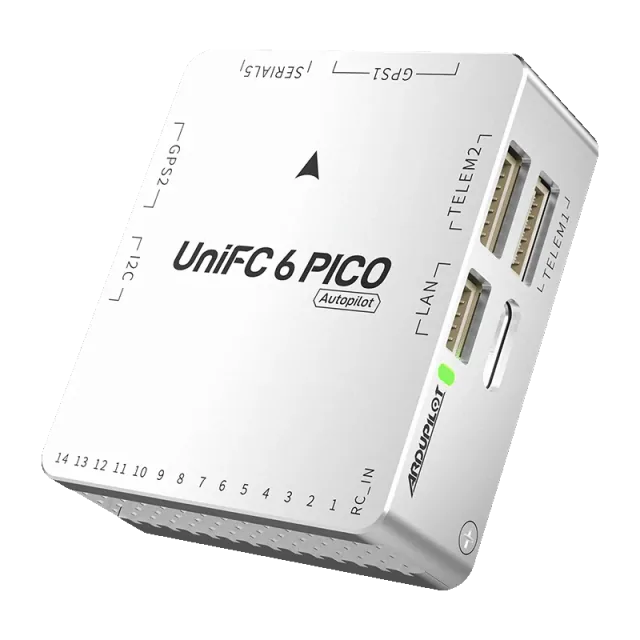
Autopilot
Compact ArduPilot / PX4 autopilot with STM32H7, dual IMU and barometer, 100 Mbps Ethernet
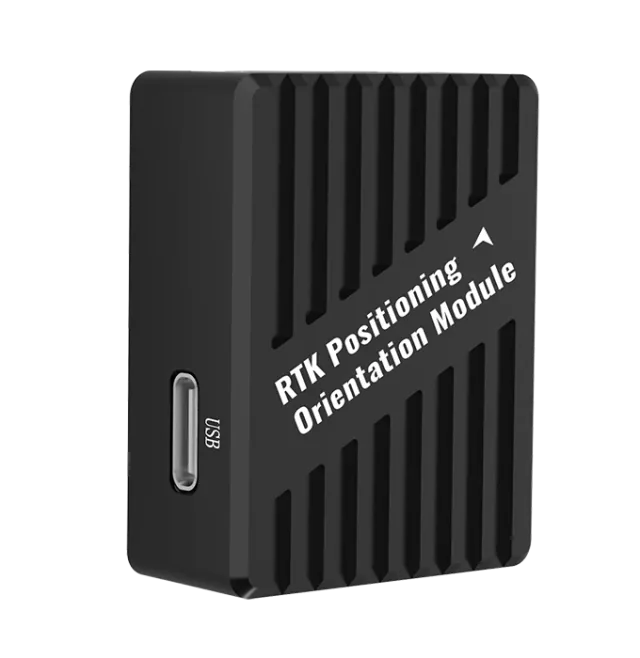
Autopilot
Single-module, dual-antenna multi-frequency RTK receiver with a PNI RM3100 compass
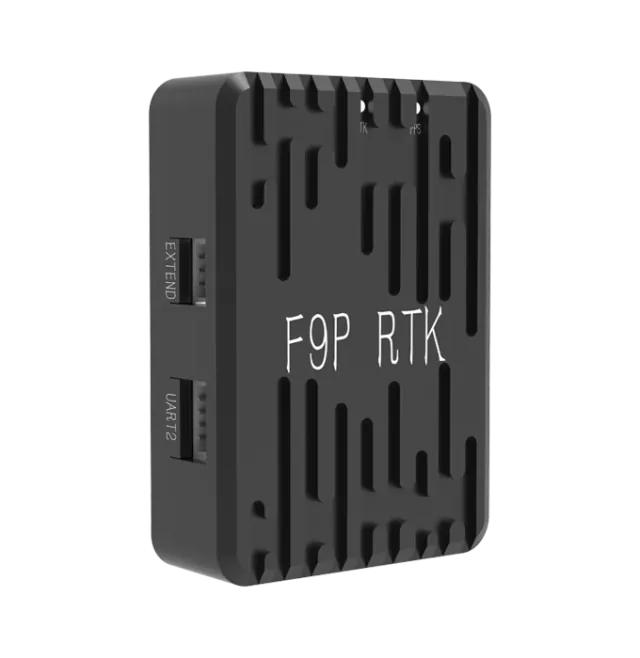
Autopilot
ZED-F9P RTK module usable as mobile station or base station, with dual-module heading
Autopilot
u-blox M10 GNSS module on DroneCAN with compass, status light, buzzer and safety switch
Send us your requirements for more information, a quotation or advice on choosing a configuration.