UAV Flight Controller Guide: Choosing an Autopilot, GNSS and RTK
What to compare when choosing a UAV flight controller: processor, sensor redundancy, interfaces and vehicle support, plus SIYI GNSS and RTK positioning modules.
Autopilot · Power Module
2–14S power module with 5.2 V output and battery voltage and current monitoring
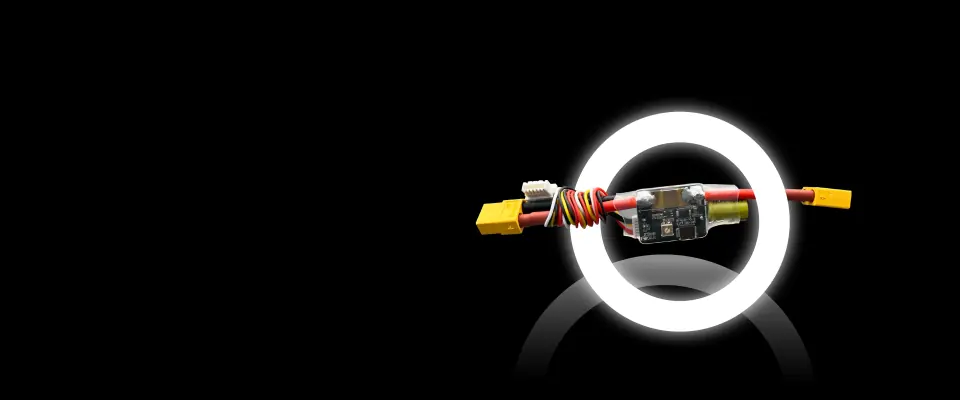
This power module supplies the N7 flight controller from a 2S to 14S battery, stepping the voltage down to a stable 5.2 V at 2 A continuous and 3 A maximum. It detects battery voltage and current, from which remaining battery power and remaining flight time are estimated. The mainboard carries 60 A constant current and 100 A peak current for under 60 s, and the BEC includes reverse protection.
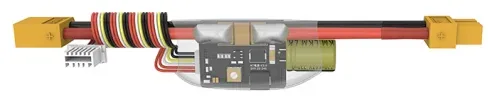
The module detects battery voltage and current so that remaining battery power can be calculated and remaining flight time estimated.
A step-down converter and BEC feed the flight controller mainboard with 5.2 V at 2 A continuous and 3 A maximum.
The mainboard carries 60 A constant current and 100 A peak current for less than 60 s. Maximum measuring current is 120 A, with a voltage divider ratio of 18.18 and 36.36 A/V.
Reverse protection on the BEC adds a layer of safety redundancy for the equipment.
The mainboard measures 23 × 29 mm and the module weighs 32 g including the connection cable and connector. The battery connector is an XT60.
| Voltage Input | 2 ~ 14 S |
|---|---|
| Voltage Output | 5.2V |
| Current Output | Continuous current: 2A Maximum current: 3A |
| Voltage Divider Ratio | 18.18 |
| A / V | 36.36 |
| Mainboard Constant Current | 60A |
| Mainboard Peak Current | 100A ( <60s ) |
| Max Measuring Current | 120A |
| Dimensions | 23 × 29 mm |
| Weight | 32g (including connection cable and connector) |
Specifications are taken from the SIYI website as of 1 October 2026 and may be revised by the manufacturer without notice. View this product on the SIYI website
SIYI has not published a reference configuration that names this model. Products in the Autopilot line are used in solutions for these platforms.
It accepts battery input from 2S to 14S.
It outputs 5.2 V, with 2 A continuous current and 3 A maximum current.
The battery connector is an XT60.
The mainboard constant current is 60 A and the peak current is 100 A for less than 60 seconds.
The current monitoring range goes up to 120 A.
Power the system from a battery, connect to the ground station and measure the battery voltage with a multimeter or battery checker. Then set the sensor version to 0 in the ground station software and type in the measured voltage; it calculates the voltage divider coefficient and saves it to the flight controller. The current reading needs no further calibration.
What to compare when choosing a UAV flight controller: processor, sensor redundancy, interfaces and vehicle support, plus SIYI GNSS and RTK positioning modules.
Autopilot
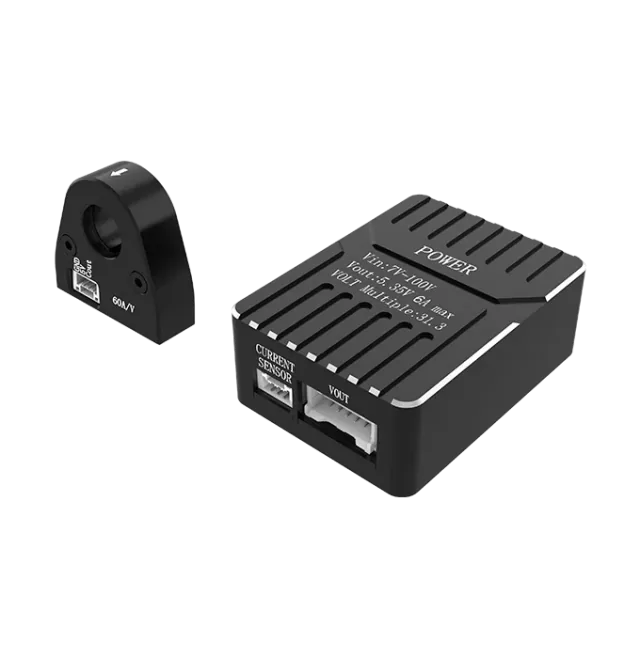
7–100 V flight controller power module with a non-contact Hall current sensor
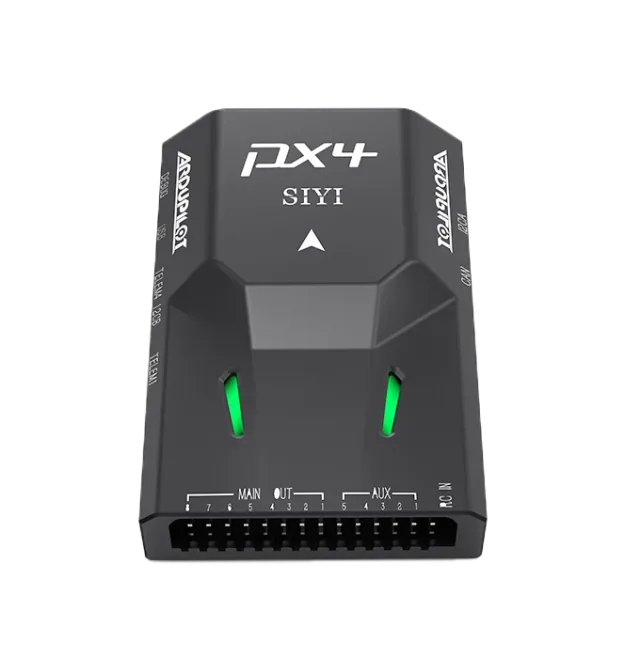
Autopilot
ArduPilot / PX4 autopilot with STM32H7, redundant dual IMUs and built-in shock absorption
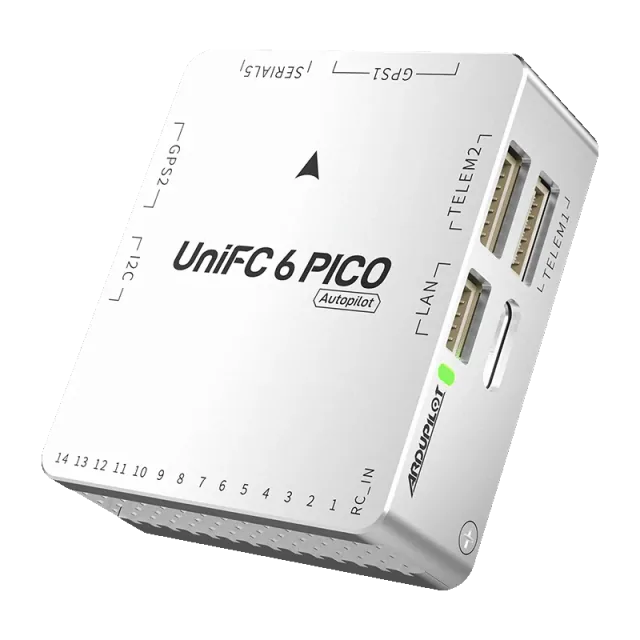
Autopilot
Compact ArduPilot / PX4 autopilot with STM32H7, dual IMU and barometer, 100 Mbps Ethernet
Autopilot
Single-module, dual-antenna multi-frequency RTK receiver with a PNI RM3100 compass
Send us your requirements for more information, a quotation or advice on choosing a configuration.